FOOD PROCESSING
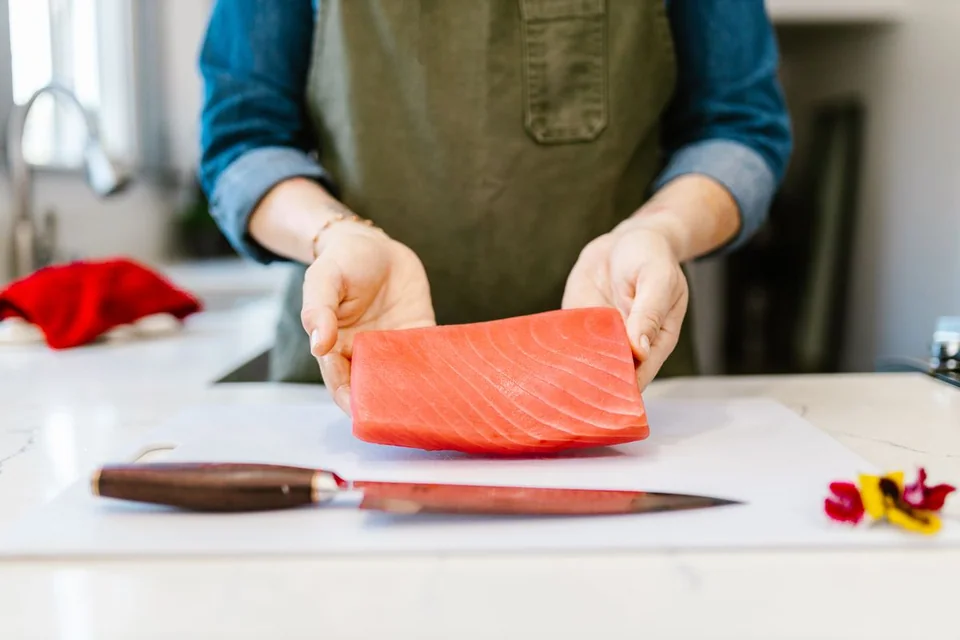
Fish & meat
Explore adaptive cutting, portioning, and handling of soft objects with changing shapes.
Potential pilot workflows$1.7TSupply chain to kitchen table
THE CONNECTION BETWEEN AGENT & BODY
Bring AI into the physical world. Somato connects reasoning, perception, and robot control—turning an objective into a path to action.
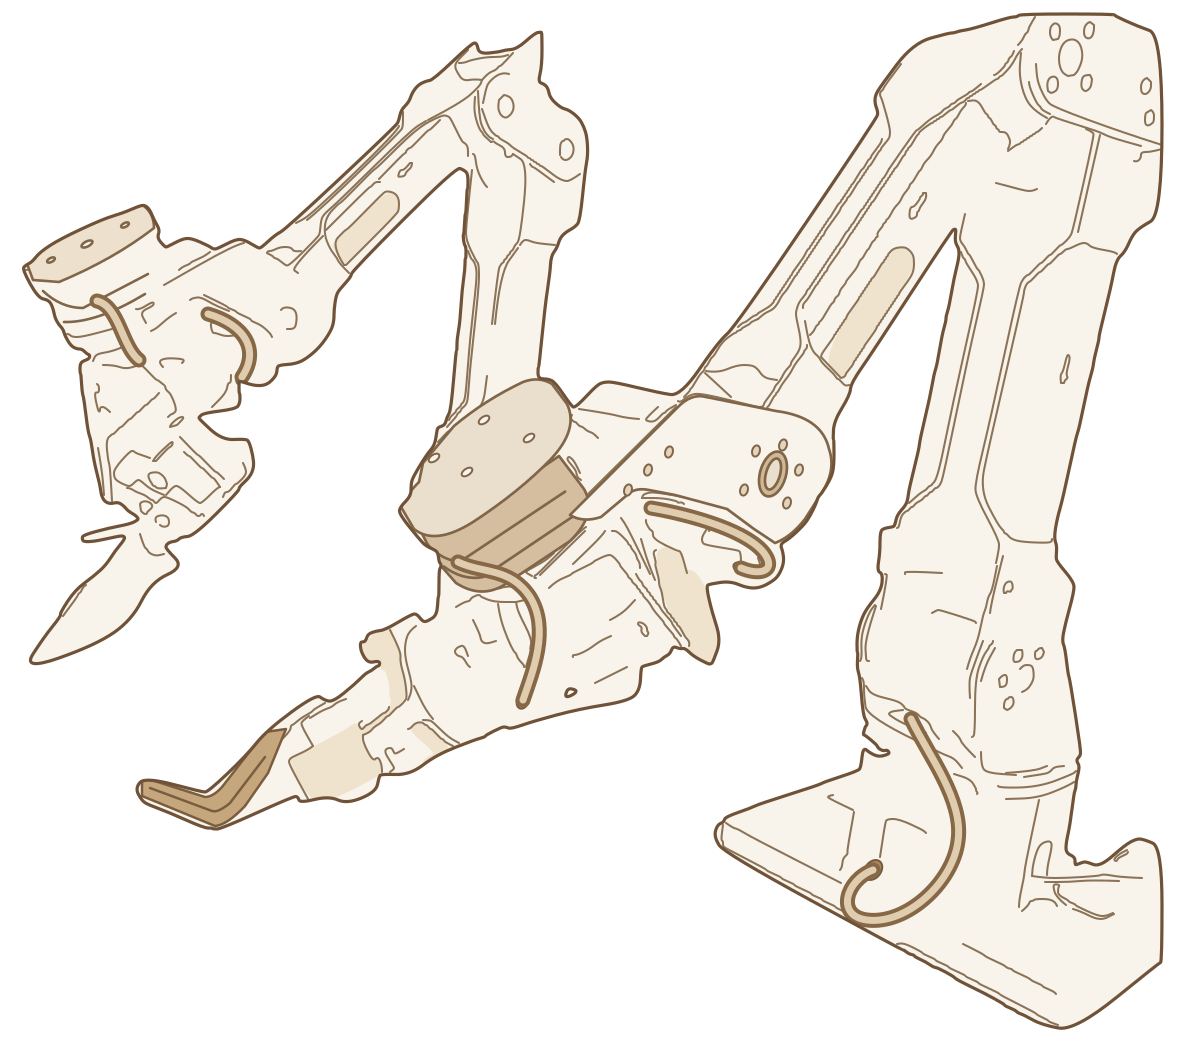
OUR DUAL-ARM REFERENCE SYSTEM
01 / APPLICATIONS & OPPORTUNITY
Some work changes with every object. Somato focuses on stationary tasks where an agent must interpret the scene, choose an operation, and adjust as conditions change.
Explore adaptive cutting, portioning, and handling of soft objects with changing shapes.
Potential pilot workflows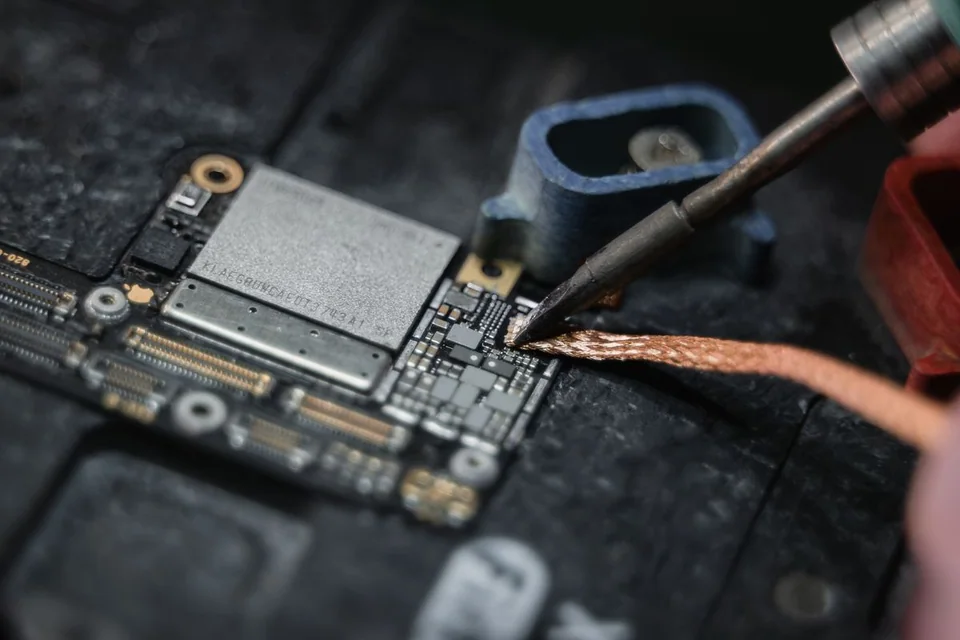
Explore inspection, precise tool positioning, and repair sequences that respond to each component.
Potential pilot workflows
Investigate how perception and precise tool control could support work in small, variable spaces.
Longer-term research direction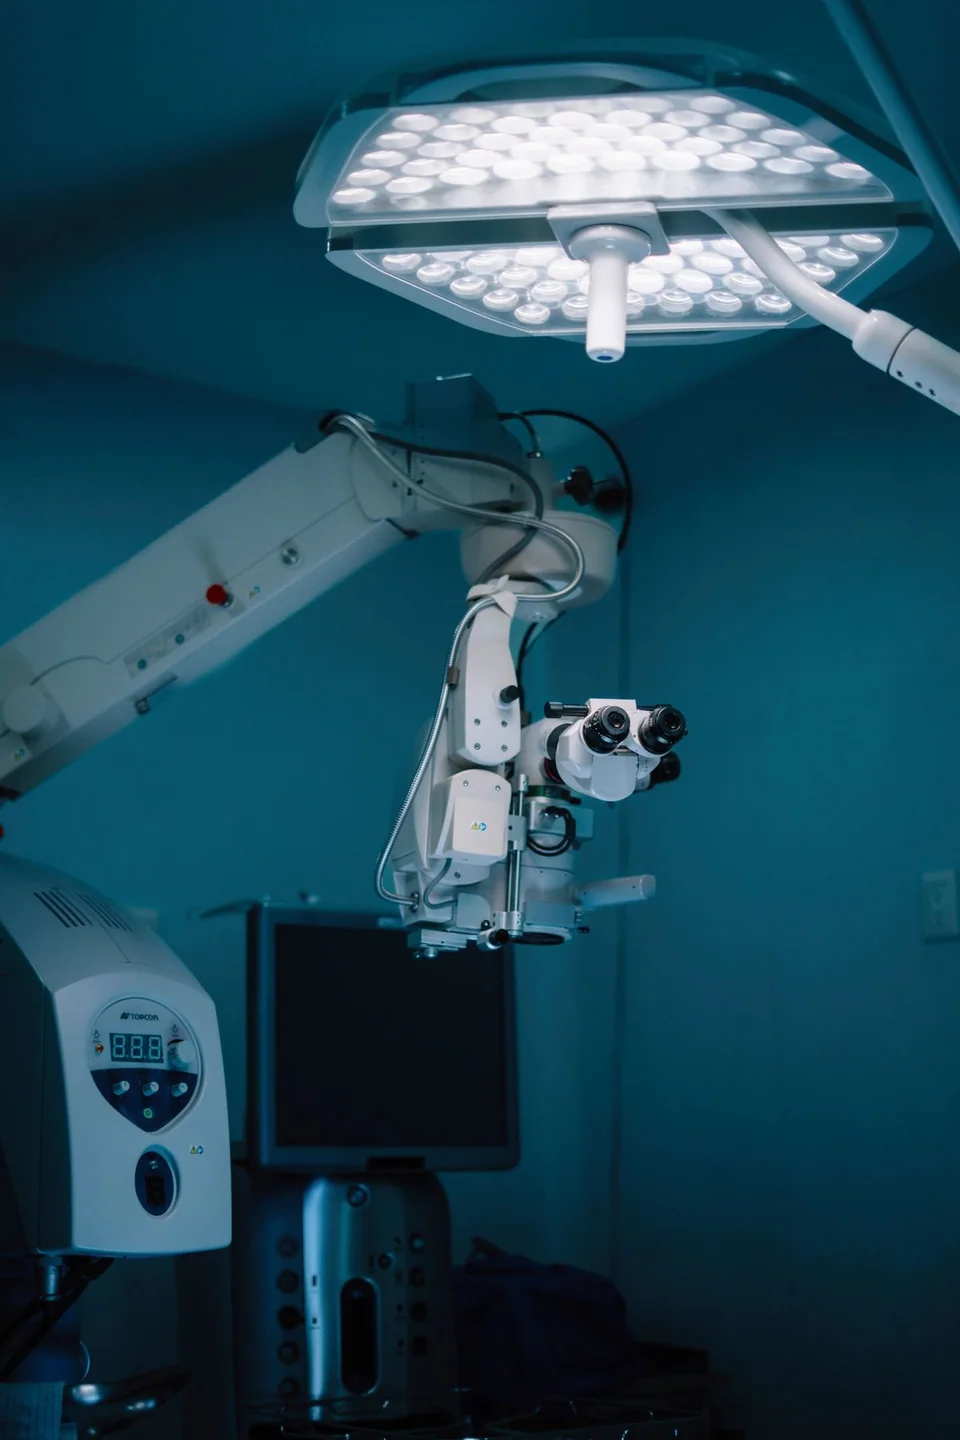
Research the connection between scene understanding and controlled tool motion in complex environments.
Longer-term research direction02 / PLATFORM & HARDWARE
Reasoning, perception, and robot control work together in a continuous loop. Our dual-arm reference system brings that architecture into the physical world.
RGB-D sensing, object understanding, and spatial tracking give the agent context tied to the scene in front of it.
The agent discovers available skills and composes a workflow. Choose the reasoning model independently from the robot interface.
Skills connect observations to spatial targets. Dedicated controllers manage the robot’s motion and report what completed.
Fresh observations and execution results return to the agent, supporting the next decision, a revised plan, or a recovery step.
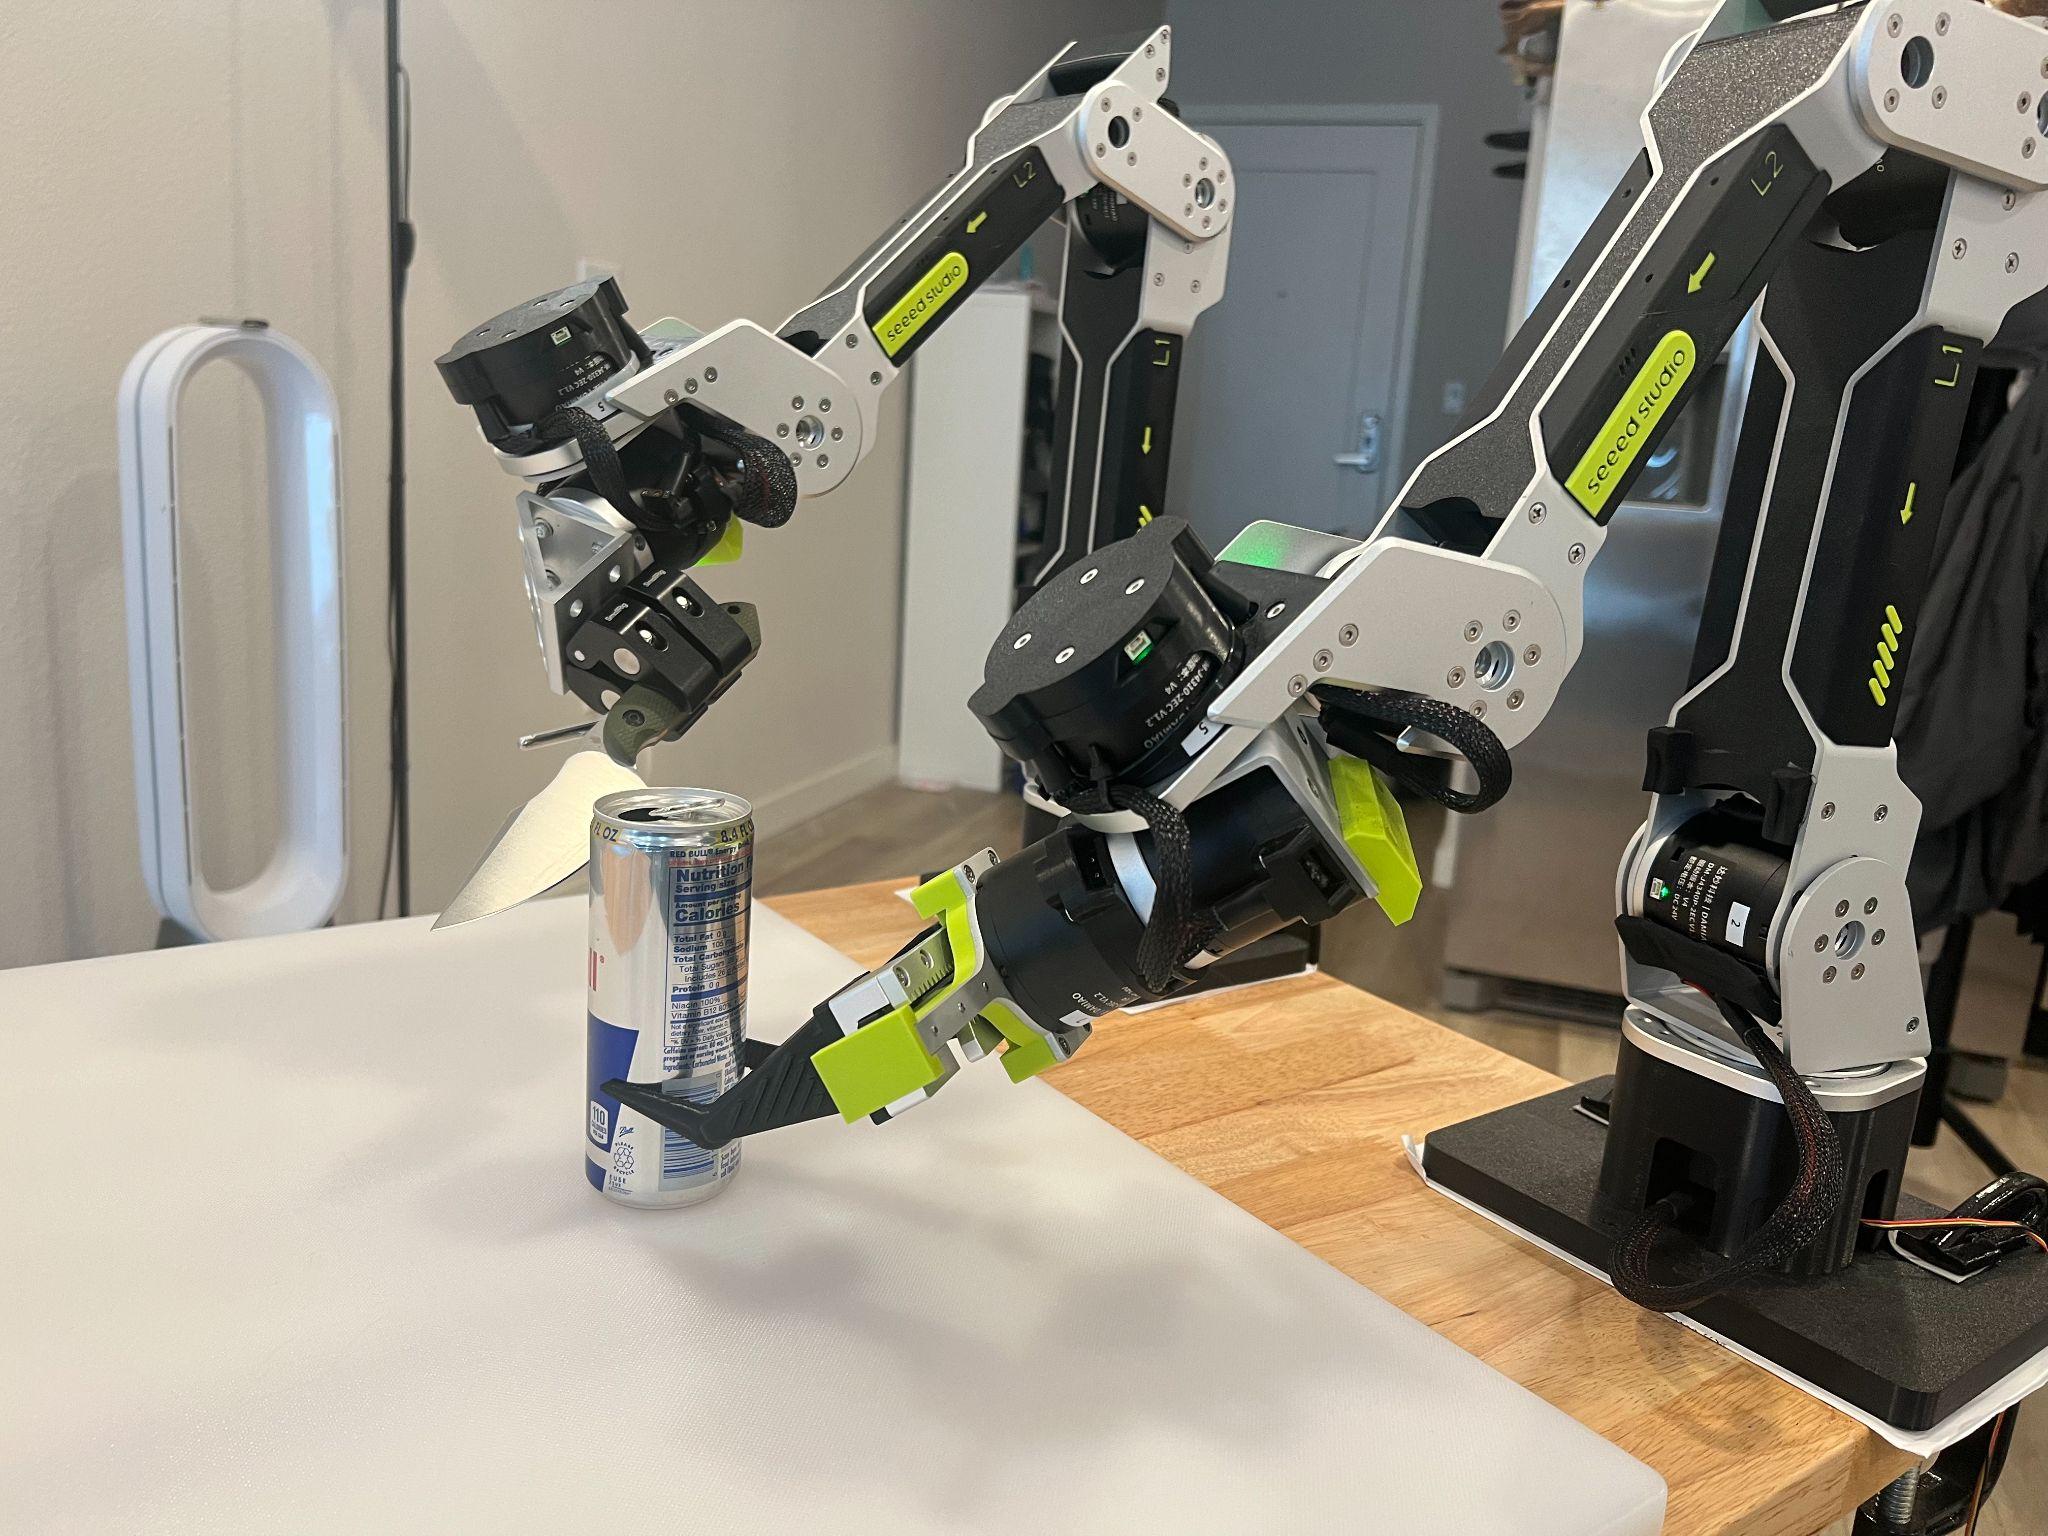
THE REFERENCE SYSTEM
Somato is developed on a tabletop workcell where perception, reasoning, and manipulation meet. It is the starting point for exploring new workflows and hardware integrations.
An experimental platform under active development.
INSPIRED BY HOW WE MOVE
A thoughtful decision and a precise movement happen at different speeds. Our architecture gives each its own place.
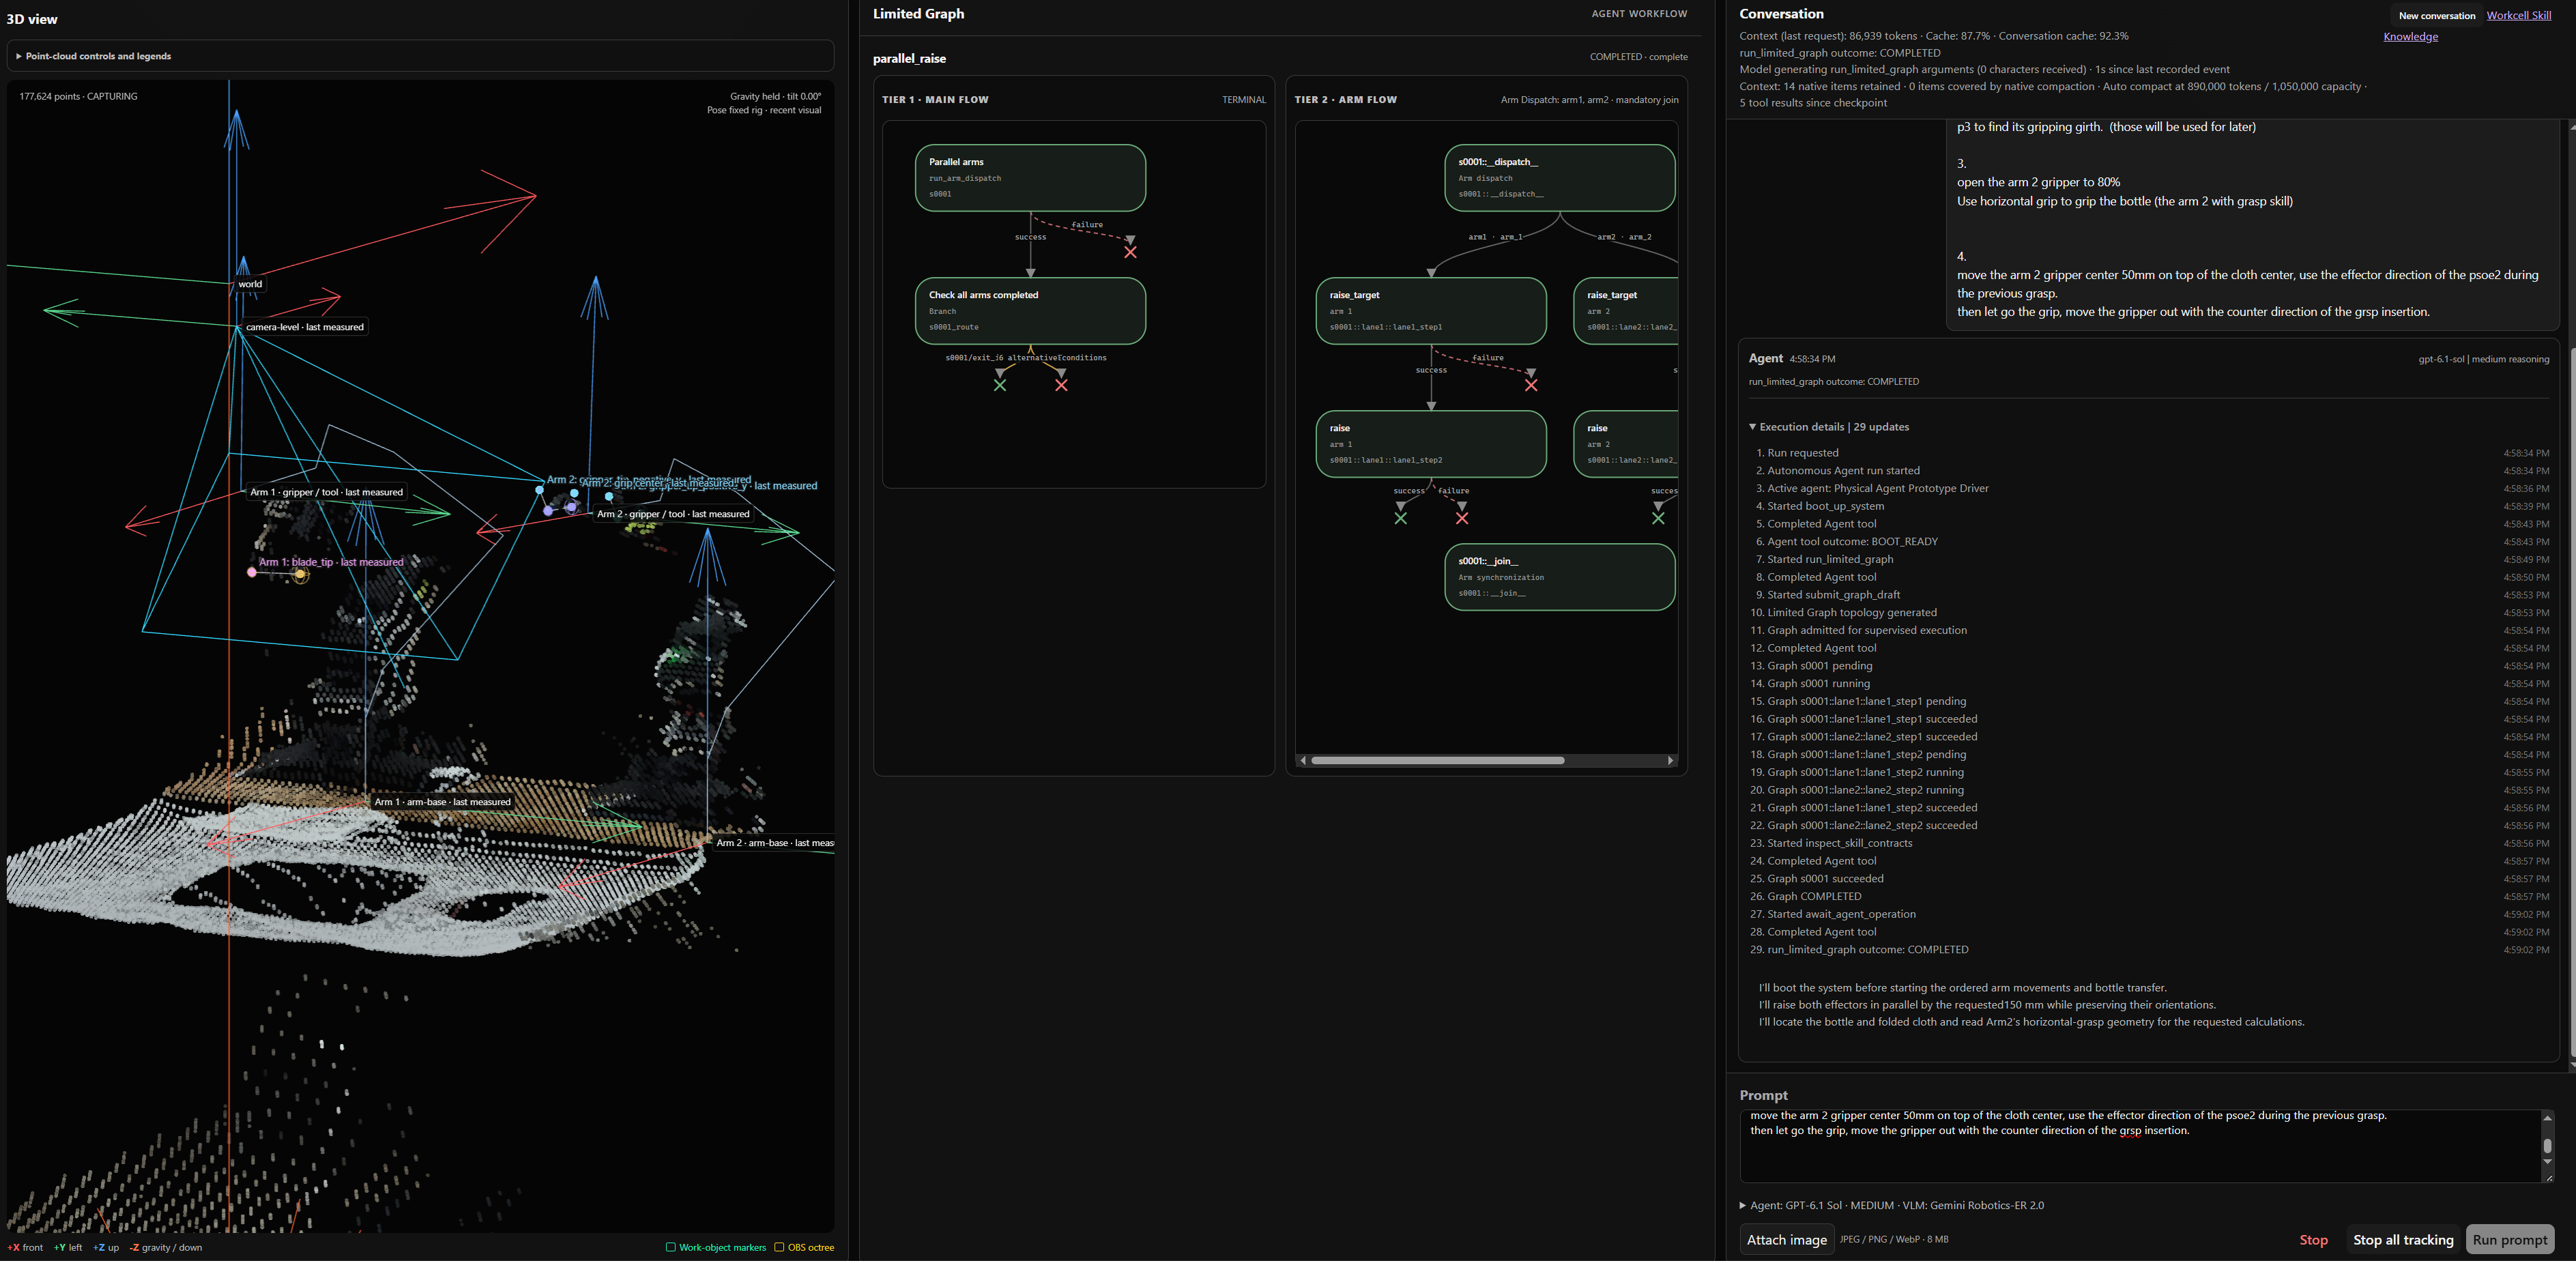
Language and vision models interpret the objective, consider the scene, and decide what to do next.
The agent
Reusable skills and workflow graphs connect perception, planning, and manipulation into finite operations.
Skills & graphs
Geometry and dedicated hardware controllers translate targets into movement, with feedback from the robot.
The control layerActual development interface · Select a view to explore.
03 / BUILD WITH SOMATO
Start with a real task and a shared question: what could your robot do with an agent in the loop?
Add an agent-directed workflow to your existing hardware. Explore integration through a defined interface, a focused task, and a jointly scoped pilot.
Develop workflows for visually guided handling and workpiece manipulation. Bring the task and process knowledge; explore the agent, perception, and control layers with us.
Explore how your agent, model, or hardware could work with Somato. Define a research question, a focused integration, and the evidence needed to evaluate it.
One task. Your hardware. A practical path from integration to evaluation.
04 / OUR POINT OF VIEW
Our starting point is a connection familiar to neuroscience: reasoning and movement are different parts of one system. The world supplies feedback. The next action responds.
Somato brings that perspective to robotics, connecting modern AI with the practical demands of perception and physical control.
A FEW GOOD QUESTIONS
Somato is a software platform connecting AI agents, perception, and robot control. Our dual-arm reference workcell is where we develop and evaluate those connections. Hardware integration is part of a scoped partner project.
The current reference system uses reBot B601-DM arms and an Orbbec Femto Bolt camera. The architecture separates hardware interfaces from agent logic. Supporting a new arm family requires integration and qualification; universal hardware compatibility is not yet established.
Model choice is separate from robot interfaces. The reference agent supports configurable hosted OpenAI, Google, and Anthropic models, alongside local perception models. Additional agents and models can be explored through the platform’s interfaces.
We start with your hardware, a specific task, and clear evaluation criteria. Together we scope the integration and the evidence needed to assess it.
LET’S CONNECT THE POSSIBILITIES
Bring a task, a platform, or an idea.
Let’s explore the connection.